
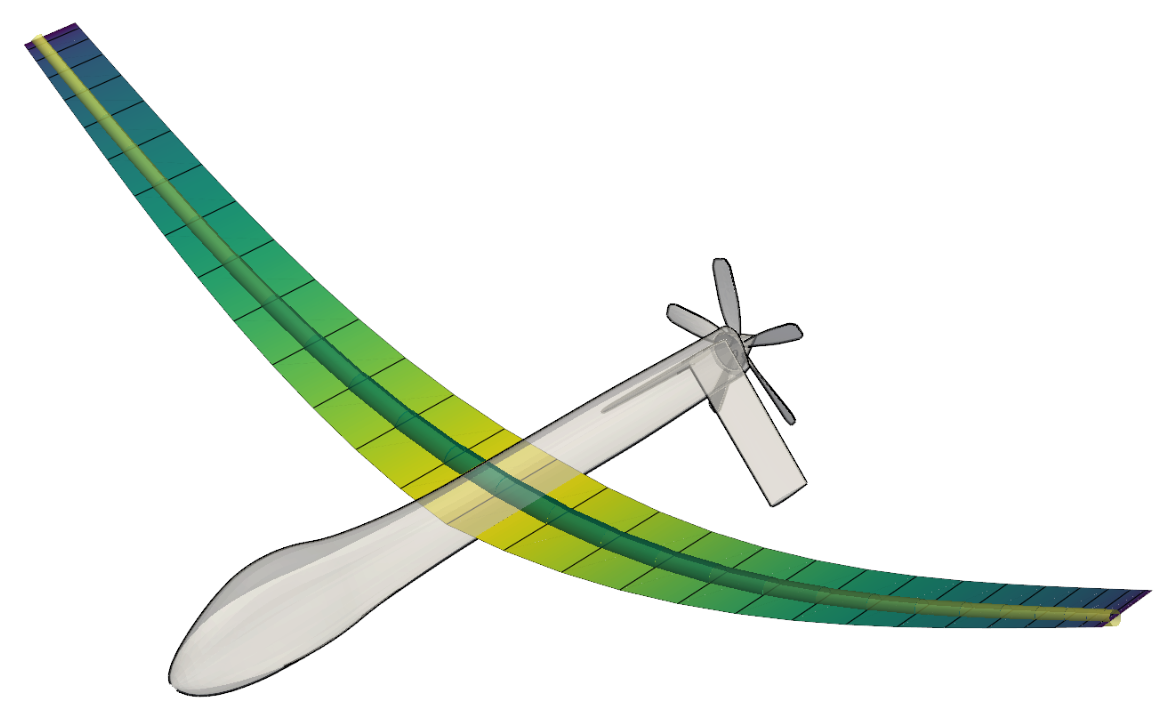
aframe is a differentiable finite-element solver for three-dimensional beam and frame structures, implemented in CSDL. It uses Euler-Bernoulli beam elements with tube, box, circular and elliptical cross sections, and recovers stress under nodal and inertial loads. Exact derivatives support structural sizing, and the robotic-fish application shows beam states driving a changing body geometry in a coupled simulation.
References
- Andrew Fletcher, Ru Xiang, Luca Scotzniovsky, Jacobo Cervera-Torralba, Michael T. Tolley, John T. Hwang. Multidisciplinary Control Co-Design Optimization of Anguilliform-Swimming Soft Fluidic Robots. IEEE International Conference on Soft Robotics (RoboSoft), 2025, 2025.PDF
@inproceedings{fletcher2025multidisciplinary,
  author = {Andrew Fletcher and Ru Xiang and Luca Scotzniovsky and Jacobo Cervera-Torralba and Michael T. Tolley and John T. Hwang},
  title = {Multidisciplinary Control Co-Design Optimization of Anguilliform-Swimming Soft Fluidic Robots},
  booktitle = {IEEE International Conference on Soft Robotics (RoboSoft)},
  year = {2025}
}
Research connections